Luca
dfd8f1d9e3
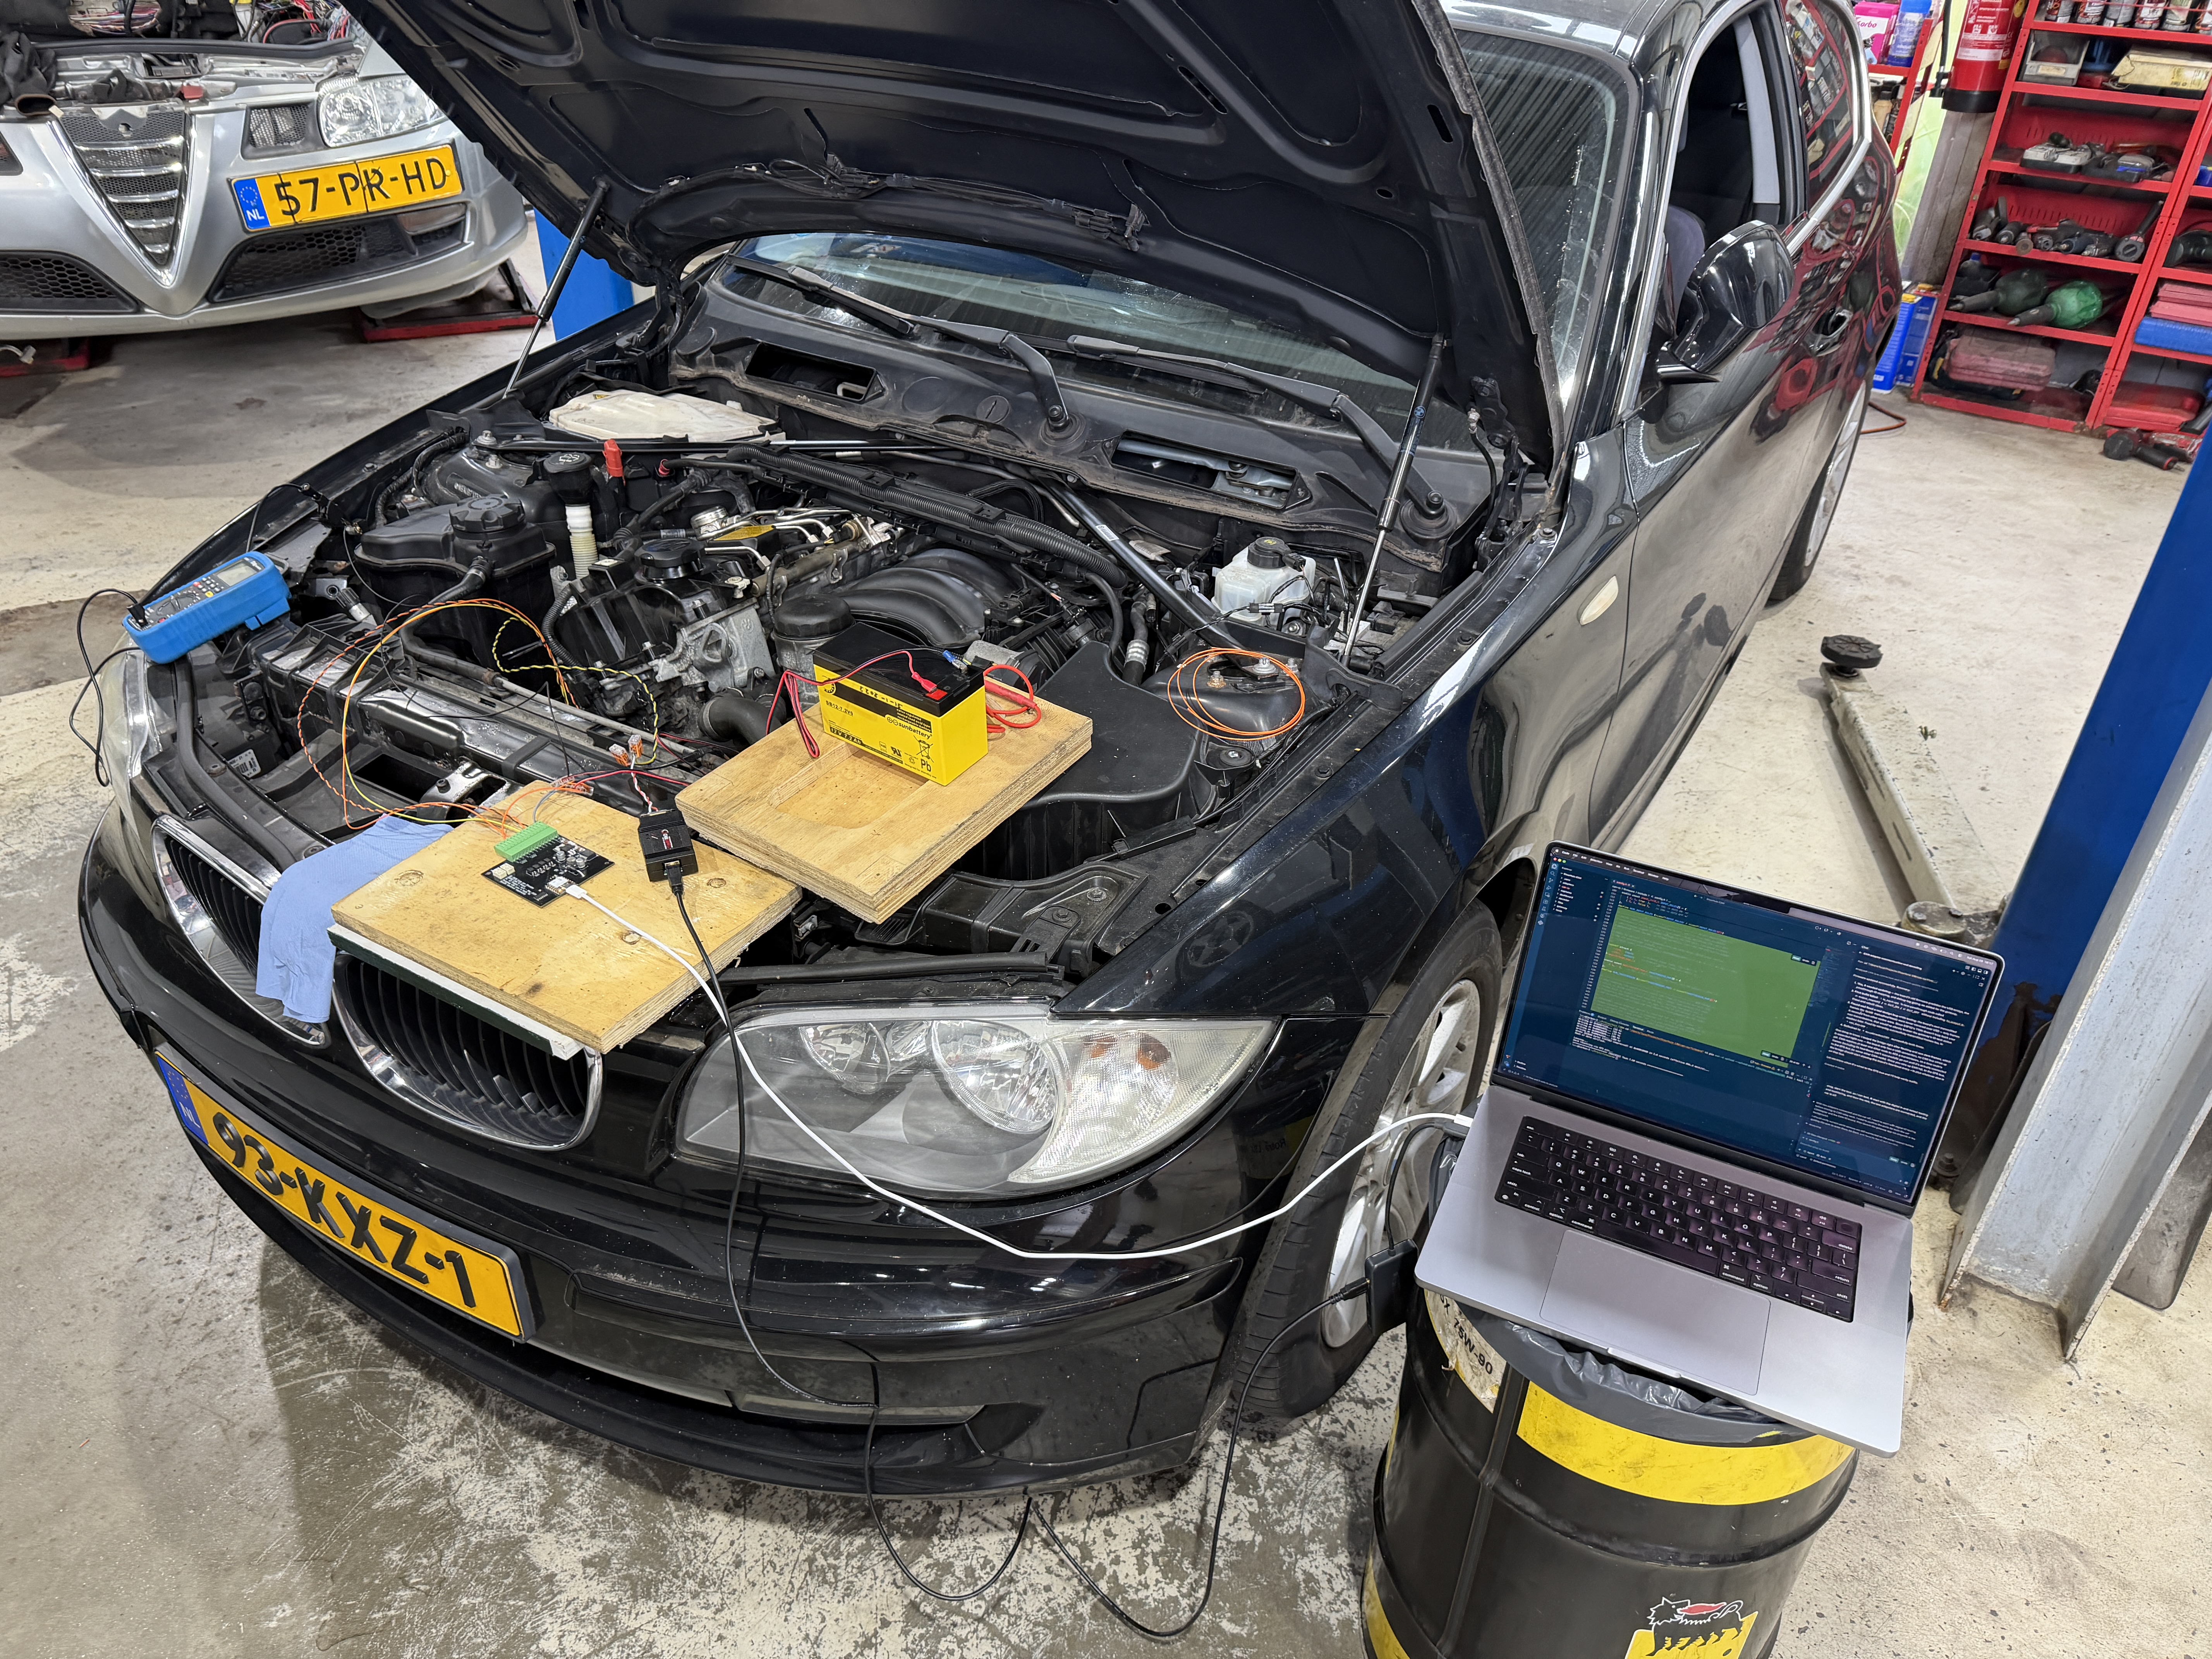
Overview of the day's work aimed at a general reader: what the EPS unit
needs, how the two-adapter bench was wired around the cut CAN bus, the
steps from transparent relay to standalone control, and the four
misleading failures along the way (frozen alive counters, transmit rate
starvation, local command dispatch, and CAN needing a second node to ACK).

Also acts as an index into the existing documentation, and pins the
direct Python dependencies the app needs.
5.8 MiB
5.8 MiB